Physicl Raises $10 Million Seed Round to Build Realistic Simulations for Training Robots
Founded by nfinite's Alex de Vigan and backed by Inovia Capital, the start-up is releasing a Studio product with 10,000 3D environments for generating synthetic robot training data.
By Nakoda News Desk
·2 min read
Prefer Nakoda News on Google
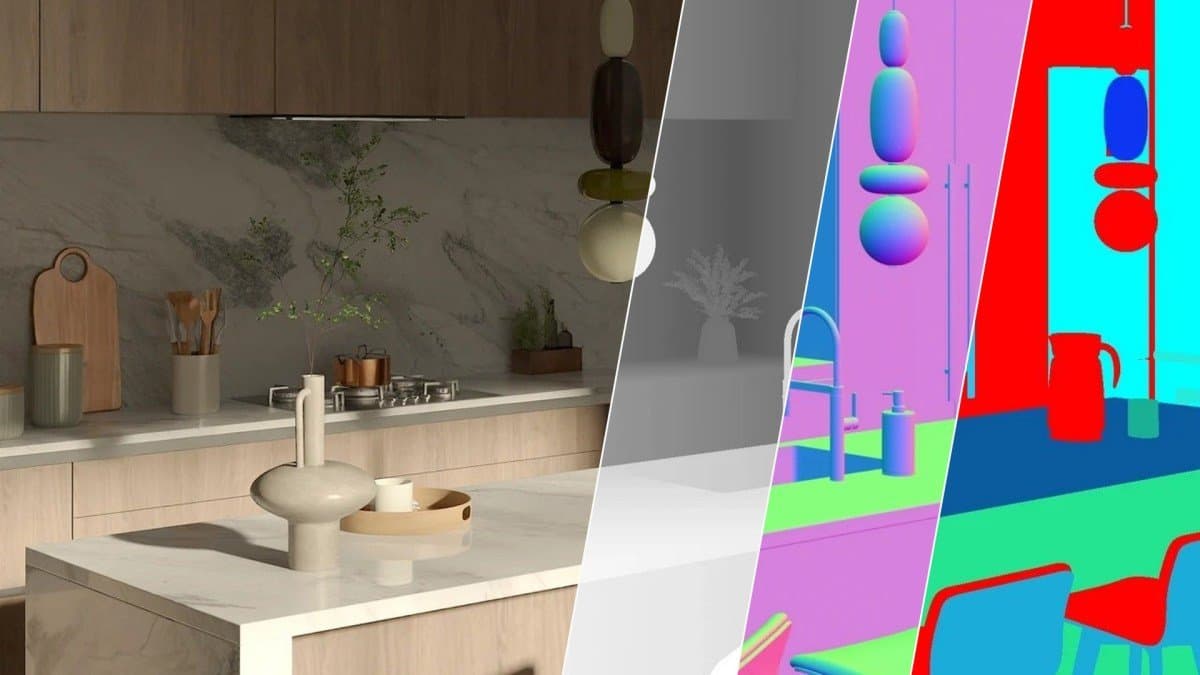
Physicl, a start-up that converts messy real-world data into physically accurate 3D scenes for training robots, has raised $10 million in seed funding from Inovia Capital.
The company is founded and run by Alex de Vigan, who spent the past decade building nfinite. That business made 3D models of products so brands and retailers could show them online, and it moved towards generative imagery once transformer-based AI arrived. De Vigan told TechCrunch that generative AI was set to replace much of what his team did in 3D, but that AI still lacked an understanding of space and objects and how to handle them. He is now pointing the rendering pipeline nfinite built at that gap.
The bet targets one of the main bottlenecks in physical AI. Developers trying to teach robots to handle varied, small objects have had disappointing results from training on video, and collecting data by operating robots remotely is expensive. Simulated worlds are a cheaper alternative, but making them obey real-world physics closely enough to be useful has proved hard. De Vigan says the pipeline can take information that is "unstructured, incomplete, heterogeneous" and turn it into a representation with correct geometry, materials and physics.
Physicl is aiming at post-training, the stage where models are refined on difficult edge cases. Its first product, Studio, comes with 10,000 3D environments and 100,000 object assets. Customers use it to build scenes and generate synthetic data for specific failures, such as a robot that cannot pick out a cup on a cluttered counter, or a cup sitting in shadow.
An early customer is SpAItial, a world model developer that generates 3D simulations from 2D images and released its latest model, Echo-3, last week. Its founder and chief executive, Matthias Niessner, a professor at the Technical University of Munich, said his team needed high-fidelity synthetic data of the kind Physicl produces. He told TechCrunch that curating such data by hand is "a very long cycle", and that the appeal is being able to generate more of a particular kind of data automatically while a model is still training.
The start-up is entering a crowded field of companies that collect, label or generate data for robot makers and foundation model builders, and de Vigan acknowledged that the category is young and its boundaries unclear. He wants Physicl to be seen as ongoing tooling rather than a one-off data supplier. He described customers feeding in trillions of images or millions of hours of lidar capture and using the platform to produce billions of variations to train their models.
Sources
- TechCrunch · Physicl raises $10M to make the digital world real enough for robots
Produced with AI assistance from the sources above. How we work
By
Nakoda News Desk
Nakoda News covers AI and business. Every story links the sources it draws on; how we work is set out in our editorial standards.
Related coverage
AI Apple Explores Turning Siri Into an Autonomous Agent as Soon as Next Year, Gurman Says
11 hours ago · 2 min read
- AI
Game Decompilation Hub Decomp.dev Winds Down, Blaming Low-Effort AI Contributions
12 hours ago · 2 min read
AI METR Says Anthropic May Have Crossed Its Own 2x AI Research Acceleration Warning Line
12 hours ago · 3 min read
- AI
Dubai Media Academy Wins Arab Media AI Award at Cairo ICT for Arabic-Language Initiative
12 hours ago · 2 min read
AI Tencent's Chief AI Scientist Warns AI Is Nearing a Harmful Threshold in Biology
14 hours ago · 2 min read